Architecting Autonomous Neural Intelligence
Explore state-of-the-art AI robotics frameworks, spatial vision transformer stacks, and real-time physical simulation suites designed for bipedal and arm-manipulation platforms.
Core AI Robotics Tools
Production-grade neural controllers, spatial mapping SDKs, and hardware orchestration engines.
QuantumLoco Kinematics v4
Real-time zero-shot reinforcement learning engine optimized for bipedal balance and rough terrain dynamic stepping.
Explore Framework Engine
NeRF-SLAM Vision Suite
Dense 3D reconstruction pipeline using visual neural radiance fields for sub-centimeter robotic navigation.
Explore Vision Suite
DexterousGrasp Transformer
Multi-modal tactile perception model for high-precision robotic hand manipulation and force feedback scaling.
Explore Grasp ModelLatest Technical Research
Deep dives into physics simulation, spatial AI, and hardware orchestration.
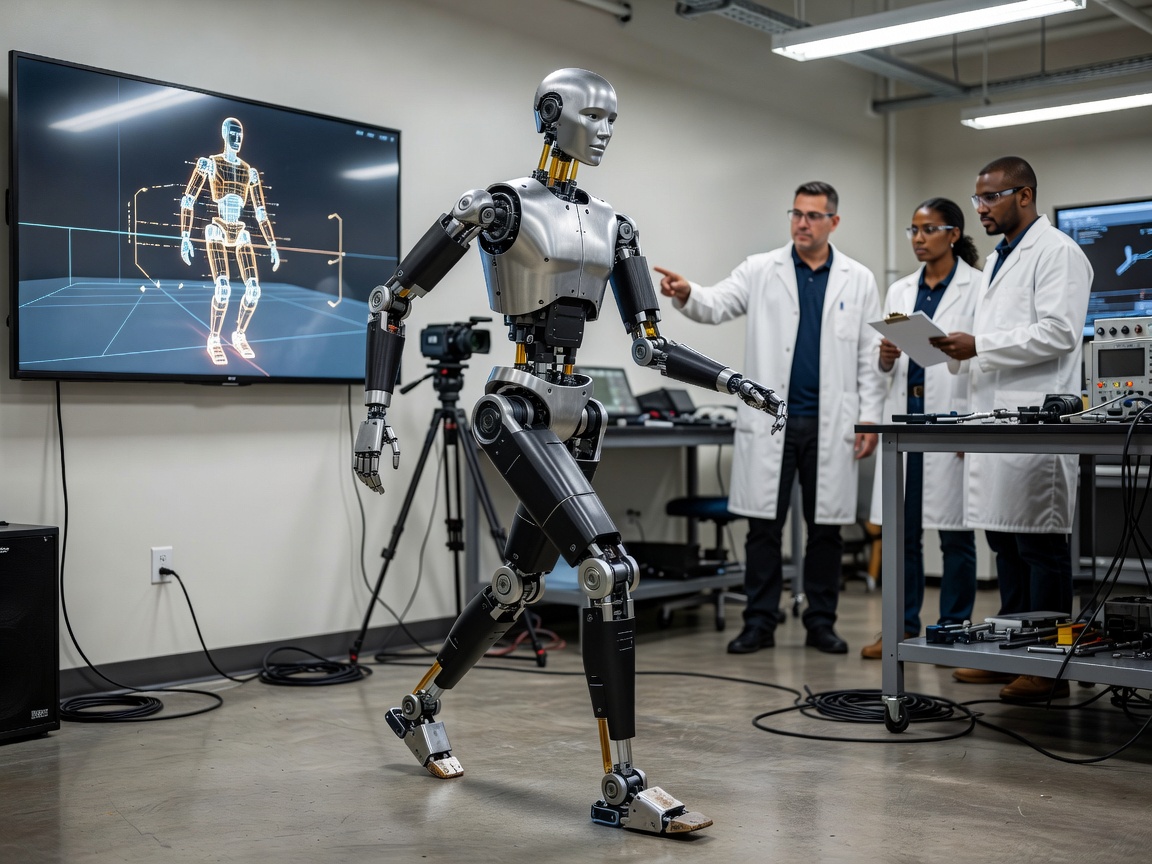
Sim-to-Real Transfer in Bipedal Locomotion
How domain randomization and physics-informed neural network architectures bridge the gap between simulation and real-world deployment.
Read Deep Dive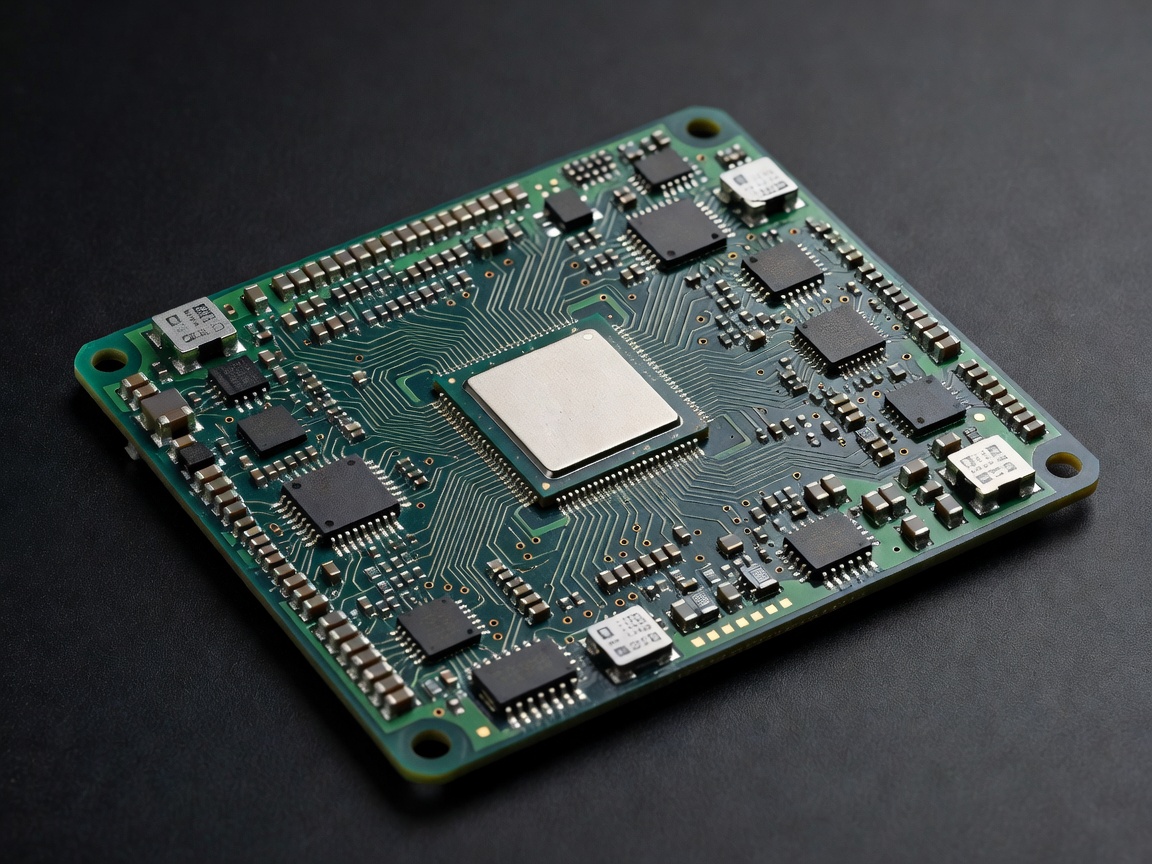
Real-Time ROS 3 Micro-Kernel Benchmarks
Benchmarking sub-millisecond latencies across distributed edge clusters in humanoid state estimation pipelines.
Read Full ArticleBuild Next-Gen Autonomous Hardware
Join over 14,000 roboticists, AI researchers, and hardware engineers utilizing Collectionsharedjourny open specifications and software suites.